
| view 👀:10 |
🙍 oneddl |
redaktor: book24h | Rating👍:
Screw Theory and its Application to Spatial Robot Manipulators [#467748]
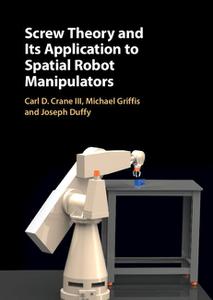
Screw Theory and its Application to Spatial Robot Manipulators
English | 2022 | ISBN: 0521630894 | 223 Pages | PDF | 5 MB
Discover a fresh take on classical screw theory and understand the geometry embedded within robots and mechanisms with this essential text. The book begins with a geometrical study of points, lines, and planes and slowly takes the reader toward a mastery of screw theory with some cutting-edge results, all while using only basic linear algebra and ordinary vectors. It features a discussion of the geometry of parallel and serial robot manipulators, in addition to the reciprocity of screws and a singularity study. All 41 essential screw systems are unveiled, establishing the possible freedom twists and constraint wrenches for a kinematic joint. Familiarizing the reader with screw geometry in order to study the statics and kinematics of robots and mechanisms, this is a perfect resource for engineers and graduate students.
Download From UploadCloud
https://www.uploadcloud.pro/y3n4ct1slc0z/c6ez2.S.T.a.i.A.t.S.R.M.rar.html
![rapidgator]()
https://rapidgator.net/file/65c20b36698f331d29c1e91b7de84505/c6ez2.S.T.a.i.A.t.S.R.M.rar.html
https://www.uploadcloud.pro/y3n4ct1slc0z/c6ez2.S.T.a.i.A.t.S.R.M.rar.html
https://rapidgator.net/file/65c20b36698f331d29c1e91b7de84505/c6ez2.S.T.a.i.A.t.S.R.M.rar.html
Please Help Me Click Connect Icon Below Here and Share News to Social Network | Thanks you !
⚠️ Dead Link ?
You may submit a re-upload request using the search feature.
All requests are reviewed in accordance with our Content Policy.
Significant surge in the popularity of free ebook download platforms. These virtual repositories offer an unparalleled range, covering genres that span from classic literature to contemporary non-fiction, and everything in between. Enthusiasts of reading can easily indulge in their passion by accessing free books download online services, which provide instant access to a wealth of knowledge and stories without the physical constraints of space or the financial burden of purchasing hardcover editions.
Comments (0)
Users of Guests are not allowed to comment this publication.